I-Nav: Reinventing Navigation When GPS Fails
2024–2025Overview
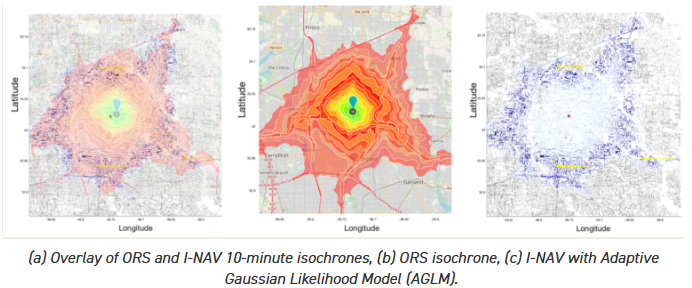
Developed a novel navigation system targeting environments where GPS signals are unavailable or unreliable — such as indoor spaces, underground structures, and urban canyons. The research was conducted at the University of Texas at Dallas and featured by the UTD ECE department. The system introduces a new approach to positioning that does not rely on satellite signals, with a patent currently pending and the research published in a 2026 journal paper.
Publication
Published Paper — Array (Elsevier), 2026 Srijeet Qazi, Justin Alejandro, Rafid Umayer Murshed, Tierra Smiley Evans, Julia Lippert, Mohammad Saquib. "I-NAV: Inverse Navigation for questionnaire-based geolocation in GPS-denied environments." Array, Volume 31, 2026, 100978. ISSN 2590-0056. https://doi.org/10.1016/j.array.2026.100978Featured Coverage
The project was highlighted by the UTD ECE department as a standout student research initiative.
Read the UTD ECE Feature →